Recorded
Real people, real homes, real factories. Egocentric and teleoperated footage captured to spec, with hand pose, depth and multi-view on request.
- Egocentric
- Teleop
- Multi-view
Robotics training data
9scale AI records, simulates and labels the data that takes robots from 90% to 99.9999% reliable.
Good enough for a demo. Not good enough for a robot working next to people.
Every extra nine needs more data — and rarer data. That is what 9scale makes.
Real people, real homes, real factories. Egocentric and teleoperated footage captured to spec, with hand pose, depth and multi-view on request.
Scenario-matched simulation that fills the long tail — the rare drops, slips and edge cases you can't wait to film in the real world.
Every frame passes through LabelNow: segment boundaries, success / failure, rewards and QA by trained reviewers before it ships.
Real robot episodes rebuilt end to end — Gaussian-splat background, generated object meshes, MuJoCo physics. Drag the seam.
Every capture is recorded so it can become a simulation environment — the same scene, the same camera, real contact physics.
0.6 mm
Median depth error on the best rebuilt object
5 / 5
±2 mm perturbation trials passed
0
Unintended contacts while lifting by physics alone
72%
Real-robot success on first deployment · zero real training data
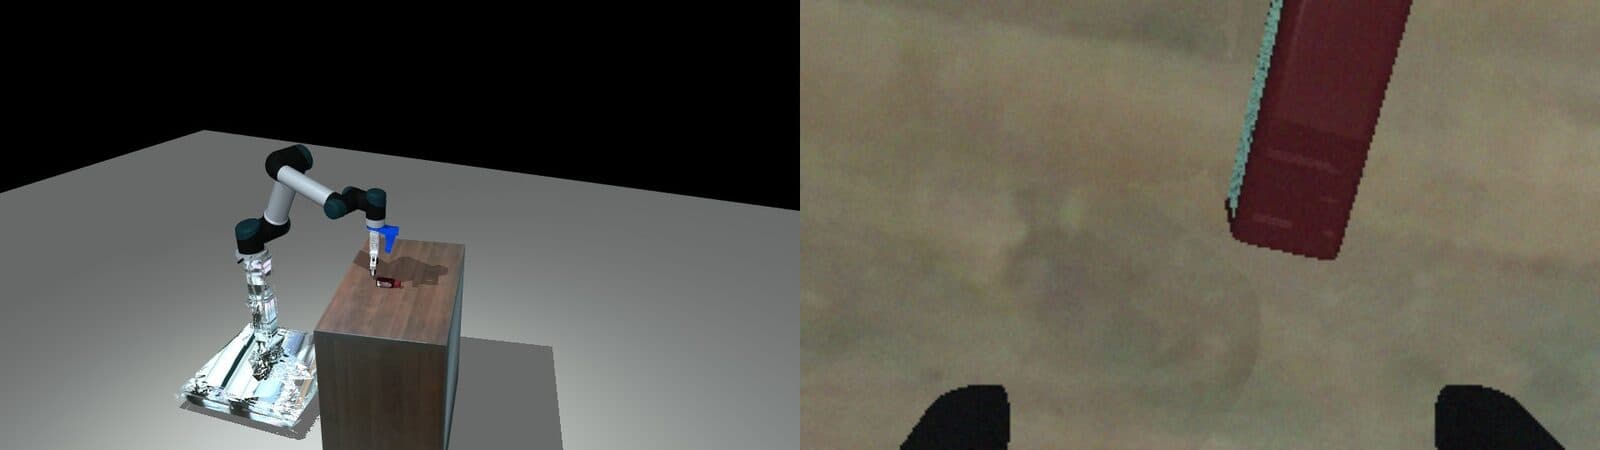
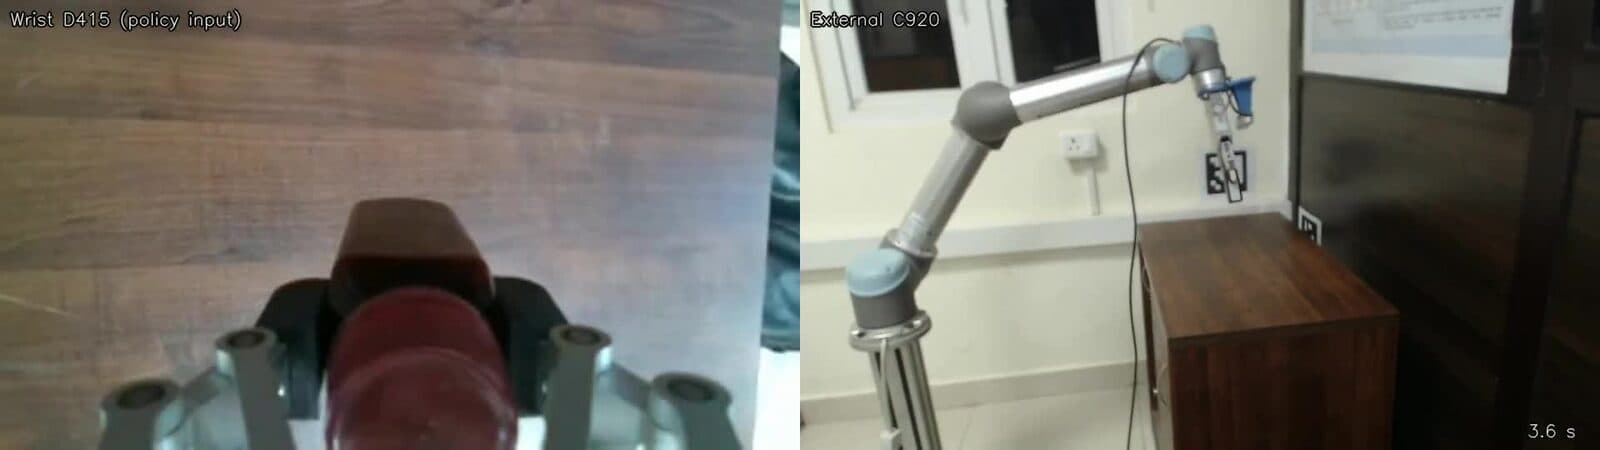
One pipeline, built on LabelNow, that turns raw human activity into training-ready robot data.
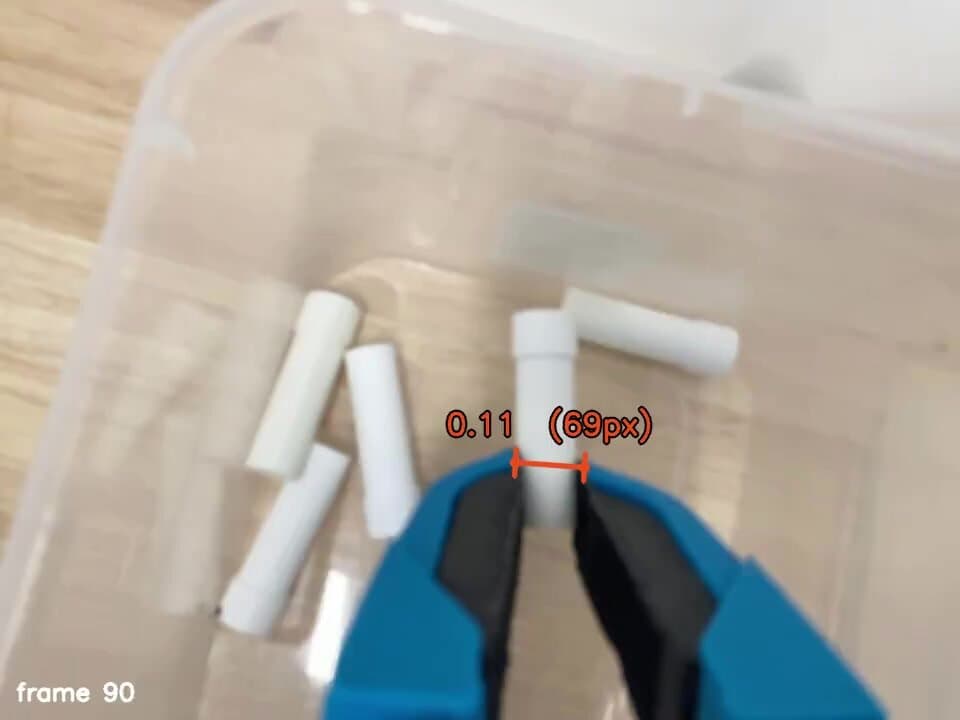
A distributed contributor network records tasks to your spec on phones and rigs.
We mirror each real task in simulation and generate the variations reality can't.
LabelNow annotates segments, outcomes and rewards — frame by frame.
Multi-pass human QA with agreement scoring. Bad frames never ship.
Training-ready datasets in your format: RLDS, LeRobot, HDF5 or raw.
72%
Real-robot success, trained only in sim
96%
Sim success after scaling up
21,504
Simulated robots practising at once
173M
Practice steps per experiment
Tell us the task. We'll send back a sample dataset.